Dongyu Yan 💫 (闫栋宇)

I'm a PhD student (2024–present), advised by Prof. Ying-Cong Chen at AI Thrust, Information Hub, Hong Kong University of Science and Technology (Guangzhou).

I earned my master's degree (2021–2024) from the School of Mechanical Engineering and Automation at Harbin Institute of Technology (Shenzhen), where I was advised by Prof. Haoyao Chen at nROS-lab. I earned my B.Eng. degree (2017–2021) from Harbin Institute of Technology.

I'm currently a research intern at LIGHTSPEED STUDIOS at Tencent IEG. Previously, I worked as a robotics research intern in the Flight Systems Department at DJI (Dec. 2021–Oct. 2022) and as a computer vision research intern in the Transformer Department at Megvii (May 2021–Aug. 2021).

Dongyu Yan profile photo

Research

My research interests include computer vision, video world models, 3D generation, and robotics. My previous research explored the intersection of implicit 3D representations and robotics, including neural reconstruction, neural SLAM, and implicit next-best-view planning. I have also worked on 3D diffusion models for geometry and texture generation. My current goal is to develop high-quality, consistent, and efficient interactive world models that could power the next generation of game engines. Below are some of my selected publications.

Selected Publications

RAR animated preview

RAR: Rate-Adaptive Rollout for Time-Consistent Interactive World Models
Yaoyang Liu*, Dongyu Yan*, Yihua Du, Shengju Qian, Zeke Xie, Xin Wang, Ying-Cong Chen, Long Chen.
arXiv preprint (2026)
arXiv / Paper / GitHub / Project Page

We propose Rate-Adaptive Rollout (RAR), which decouples the temporal rate of interactive world models from generation throughput. Stride-RoPE and synchronized multi-stride sampling support temporally consistent rollout across different rates, including unseen rates and online rate switching, while extending the physical-time horizon.
UltraShape 1.0 preview

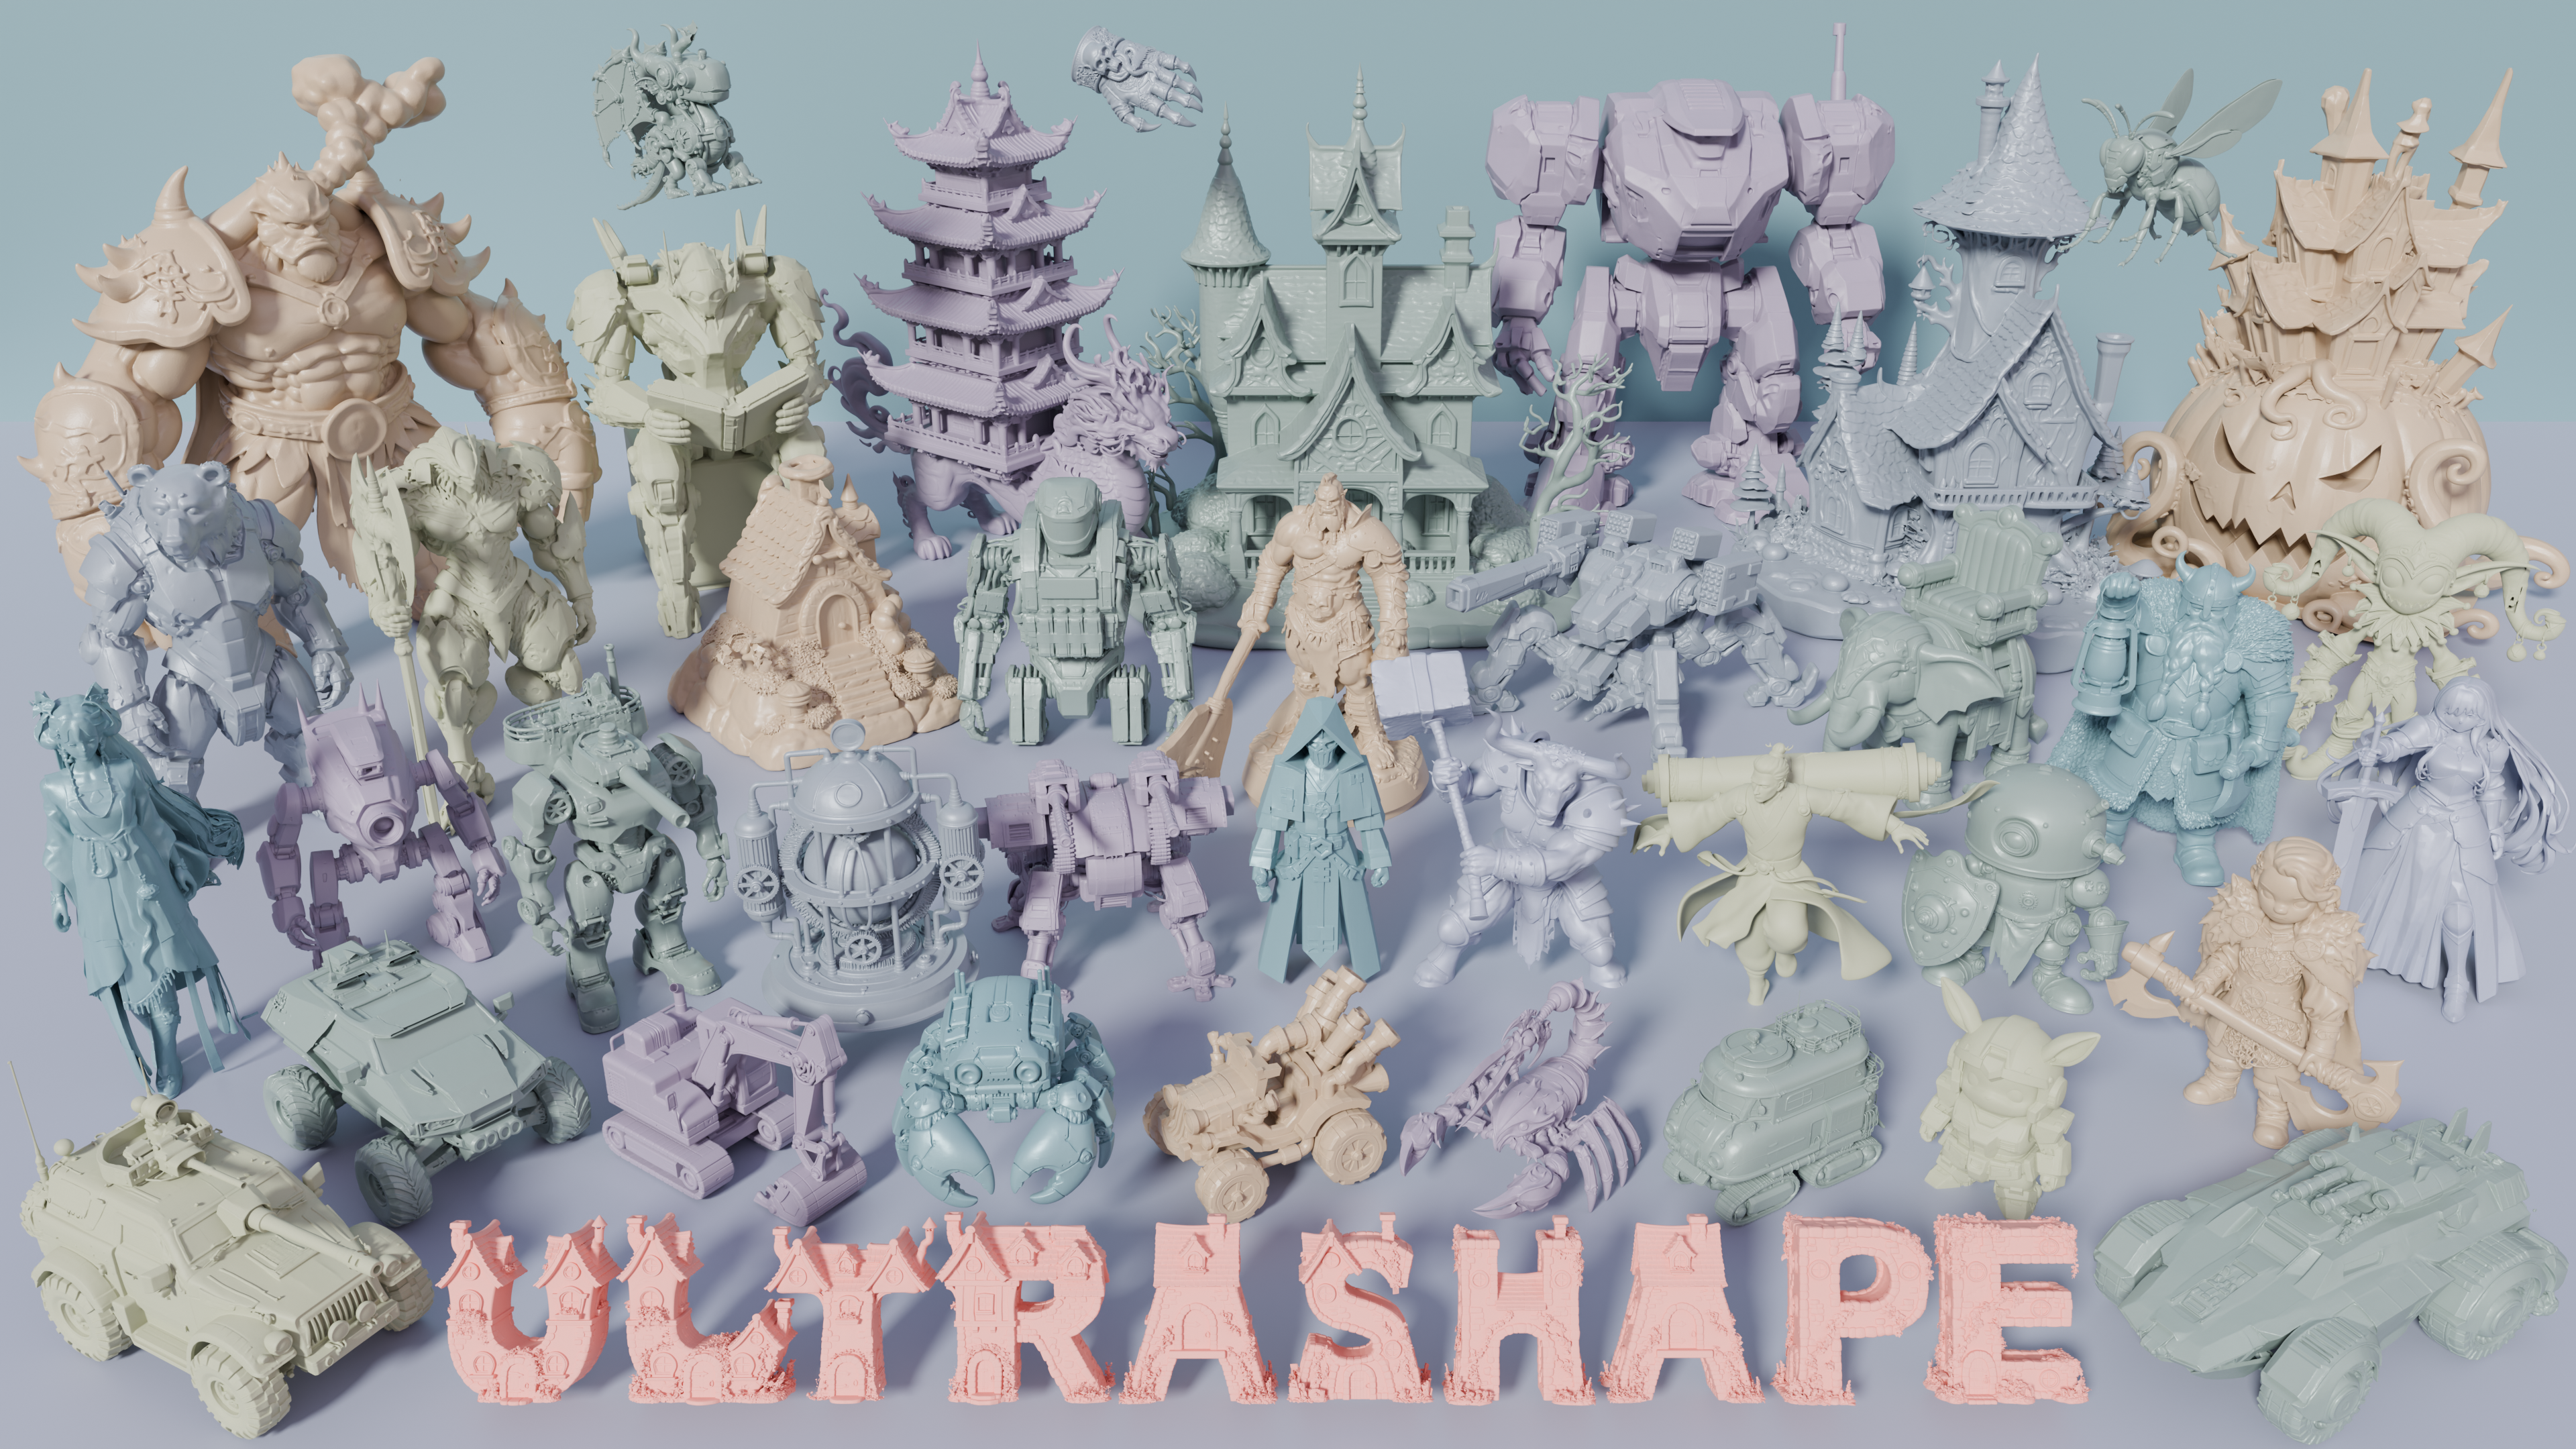
UltraShape 1.0: High-Fidelity 3D Shape Generation via Scalable Geometric Refinement
Tanghui Jia*, Dongyu Yan*, Dehao Hao*, Yang Li, Kaiyi Zhang, Xianyi He, Lanjiong Li, Yuhan Wang, Jinnan Chen, Lutao Jiang, Qishen Yin, Long Quan, Ying-Cong Chen, Li Yuan.
arXiv preprint (2025)
arXiv / Paper / GitHub / Project Page

We present a scalable two-stage 3D diffusion framework that first generates coarse geometry and then refines it into detailed, high-fidelity shapes. Geometry-aware refinement and a watertight data-processing pipeline help preserve fine details and improve generation quality.

FlexPainter texture generation preview

FlexPainter: Flexible and Multi-View Consistent Texture Generation
Dongyu Yan*, Leyi Wu*, Jiantao Lin, Luozhou Wang, Tianshuo Xu, Zhifei Chen, Zhen Yang, Lie Xu, Shunsi Zhang, Ying-Cong Chen.
arXiv preprint (2025)
arXiv / Paper / GitHub / Project Page

We introduce FlexPainter, a texture generation pipeline that supports flexible guidance from text, images, or both. Joint multi-view generation, view synchronization, and 3D-aware texture completion enable consistent, high-resolution textures for 3D assets.

MSI-NeRF preview

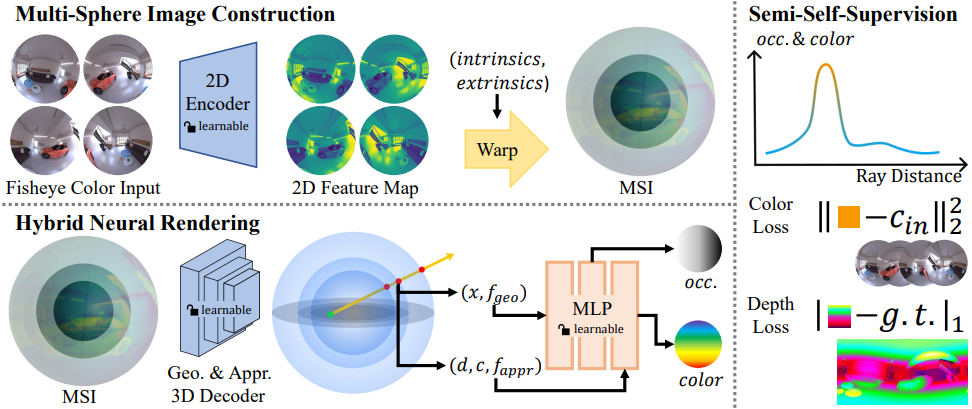
MSI-NeRF: Linking Omni-Depth with View Synthesis through Multi-Sphere Image aided Generalizable Neural Radiance Field
Dongyu Yan, Guanyu Huang, Fengyu Quan, Haoyao Chen.
IEEE/CVF Winter Conference on Applications of Computer Vision (WACV 2025)
arXiv / Paper / Video / GitHub

We propose a generalizable NeRF framework that takes four fisheye images as input and produces a 3D MSI representation for novel view synthesis and depth estimation. Trained using only synthetic depth data, the framework generalizes to a wide range of scenarios. We also release a fisheye multi-view dataset for training and evaluation.

Active implicit reconstruction preview

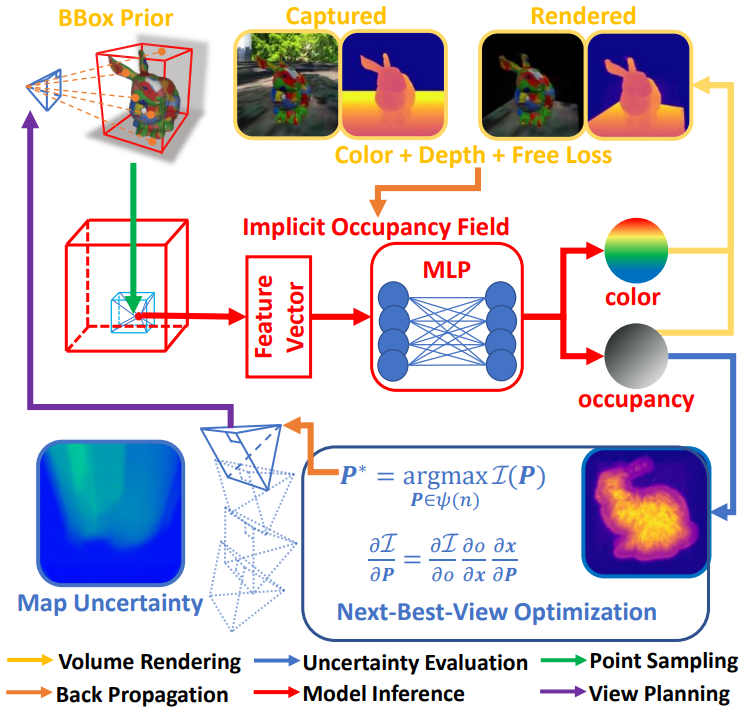
Active Implicit Object Reconstruction using Uncertainty-guided Next-Best-View Optimization
Dongyu Yan*, Jianheng Liu*, Fengyu Quan, Haoyao Chen.
IEEE Robotics and Automation Letters (RA-L 2023)
arXiv / Paper / Video / GitHub

We propose an active implicit object reconstruction method that uses uncertainty estimates from an implicit occupancy map to guide next-best-view optimization. The method optimizes a virtual camera trajectory through the uncertainty field to maximize information gain during reconstruction.

EINRUL preview

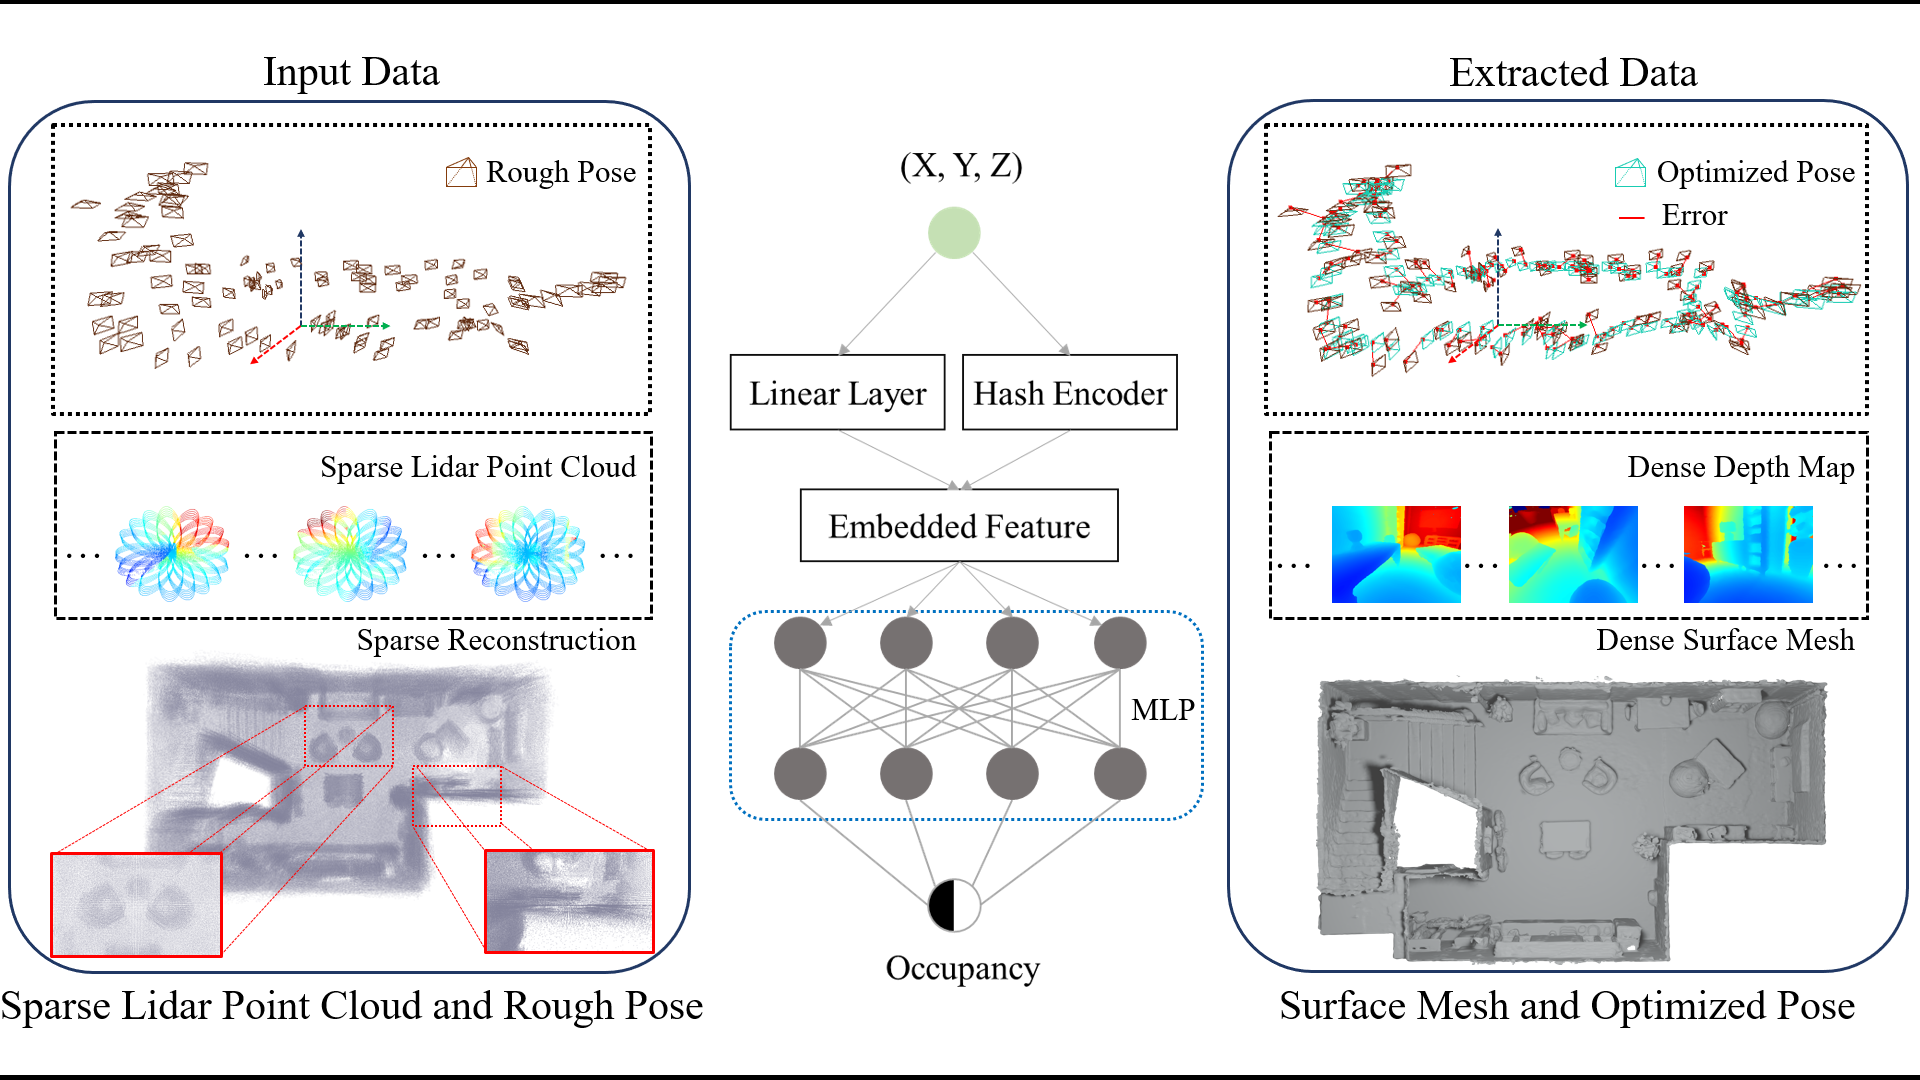
Efficient Implicit Neural Reconstruction Using LiDAR
Dongyu Yan, Xiaoyang Lyu, Jieqi Shi, Yi Lin.
IEEE International Conference on Robotics and Automation (ICRA 2023)
arXiv / Paper / Video / GitHub / Project Page

We propose an efficient and accurate implicit reconstruction method using LiDAR scans that is applicable across a range of scenarios. Our self-collected dataset demonstrates its effectiveness in real-world scenes, even with sparse LiDAR scans and poorly aligned poses.

Competitions

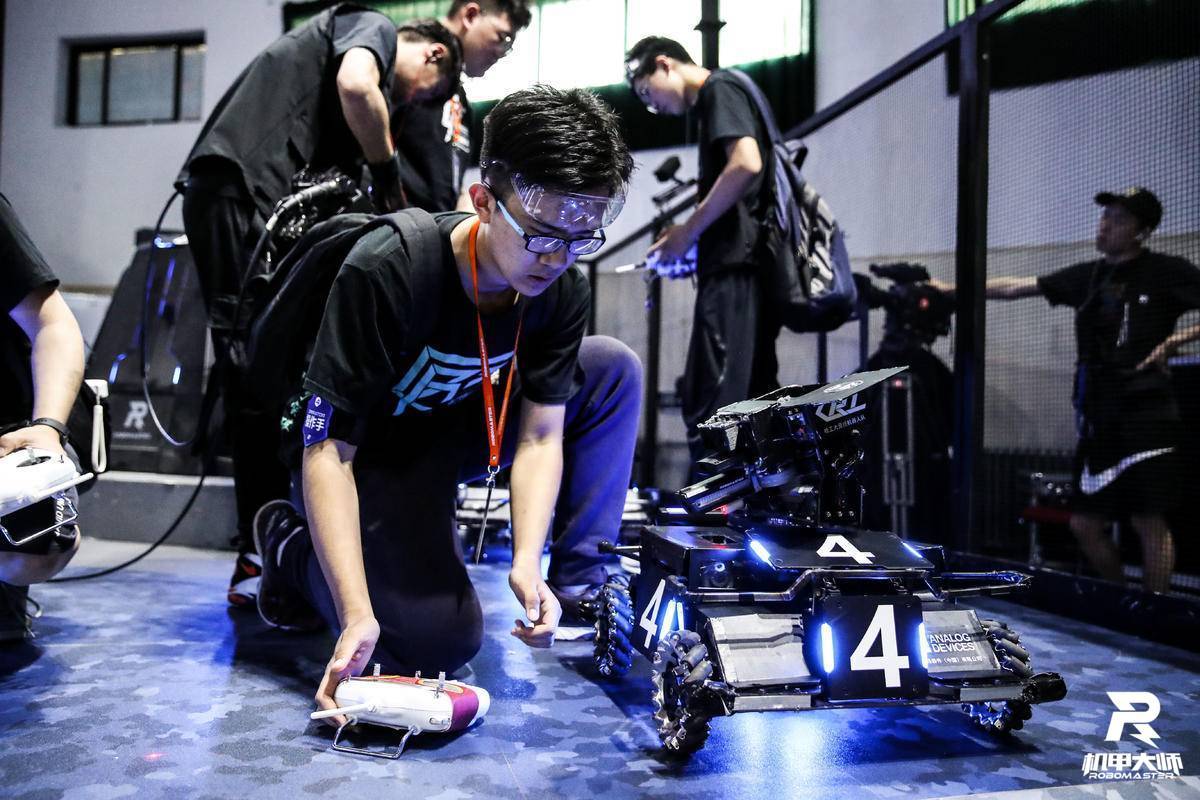
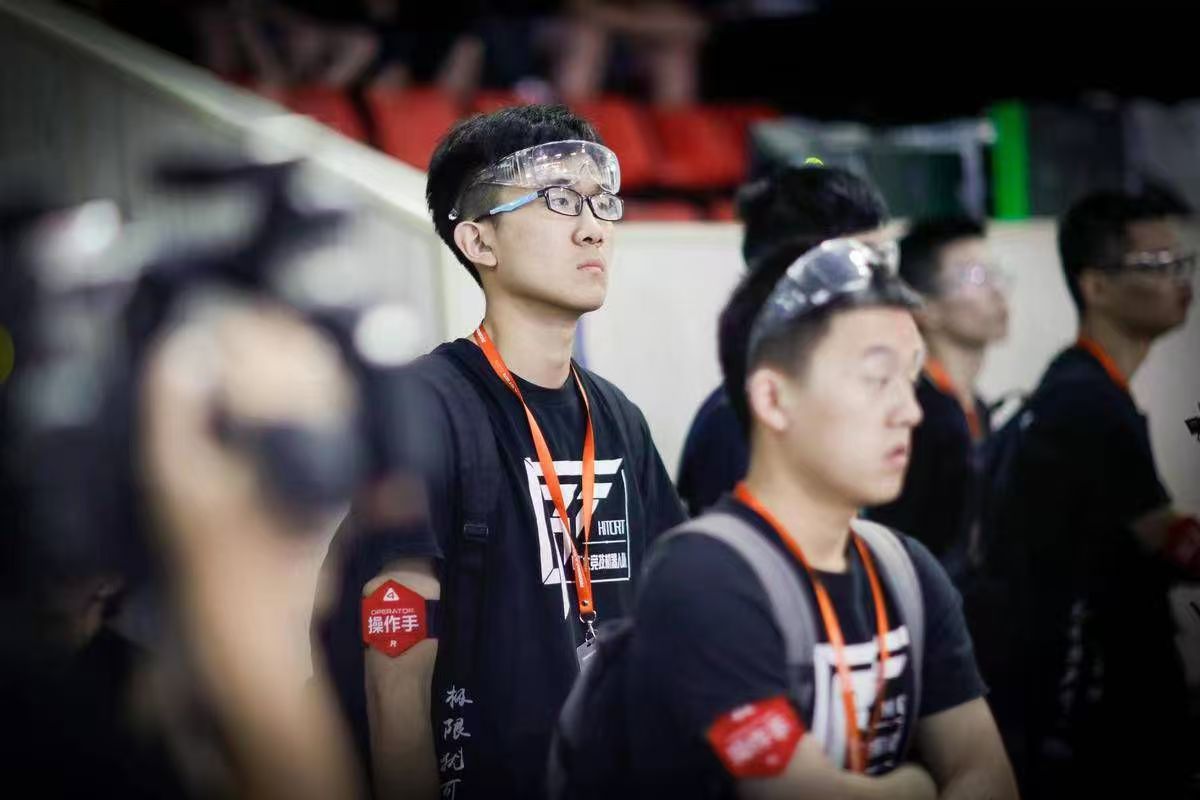
RoboMaster competition RoboMaster competition

RoboMaster 2021: 2nd Place
As the leader of the computer vision team, I was responsible for the development of the SLAM and Navigation system.

Robocon 2020 China Division: 3rd Place
As the leader of the electronic control team, I was responsible for the development of the PMSM Driver system.

RoboMaster 2019: 5th–6th Place
As a member of the electronic control team, I was responsible for the control system of the Sentry robot, and also served as a robot operator.

My time in HITCRT taught me so much and inspired me to pursue scientific research. I will always be grateful to the teammates I worked alongside, and I hope the team continues to thrive.

About Me

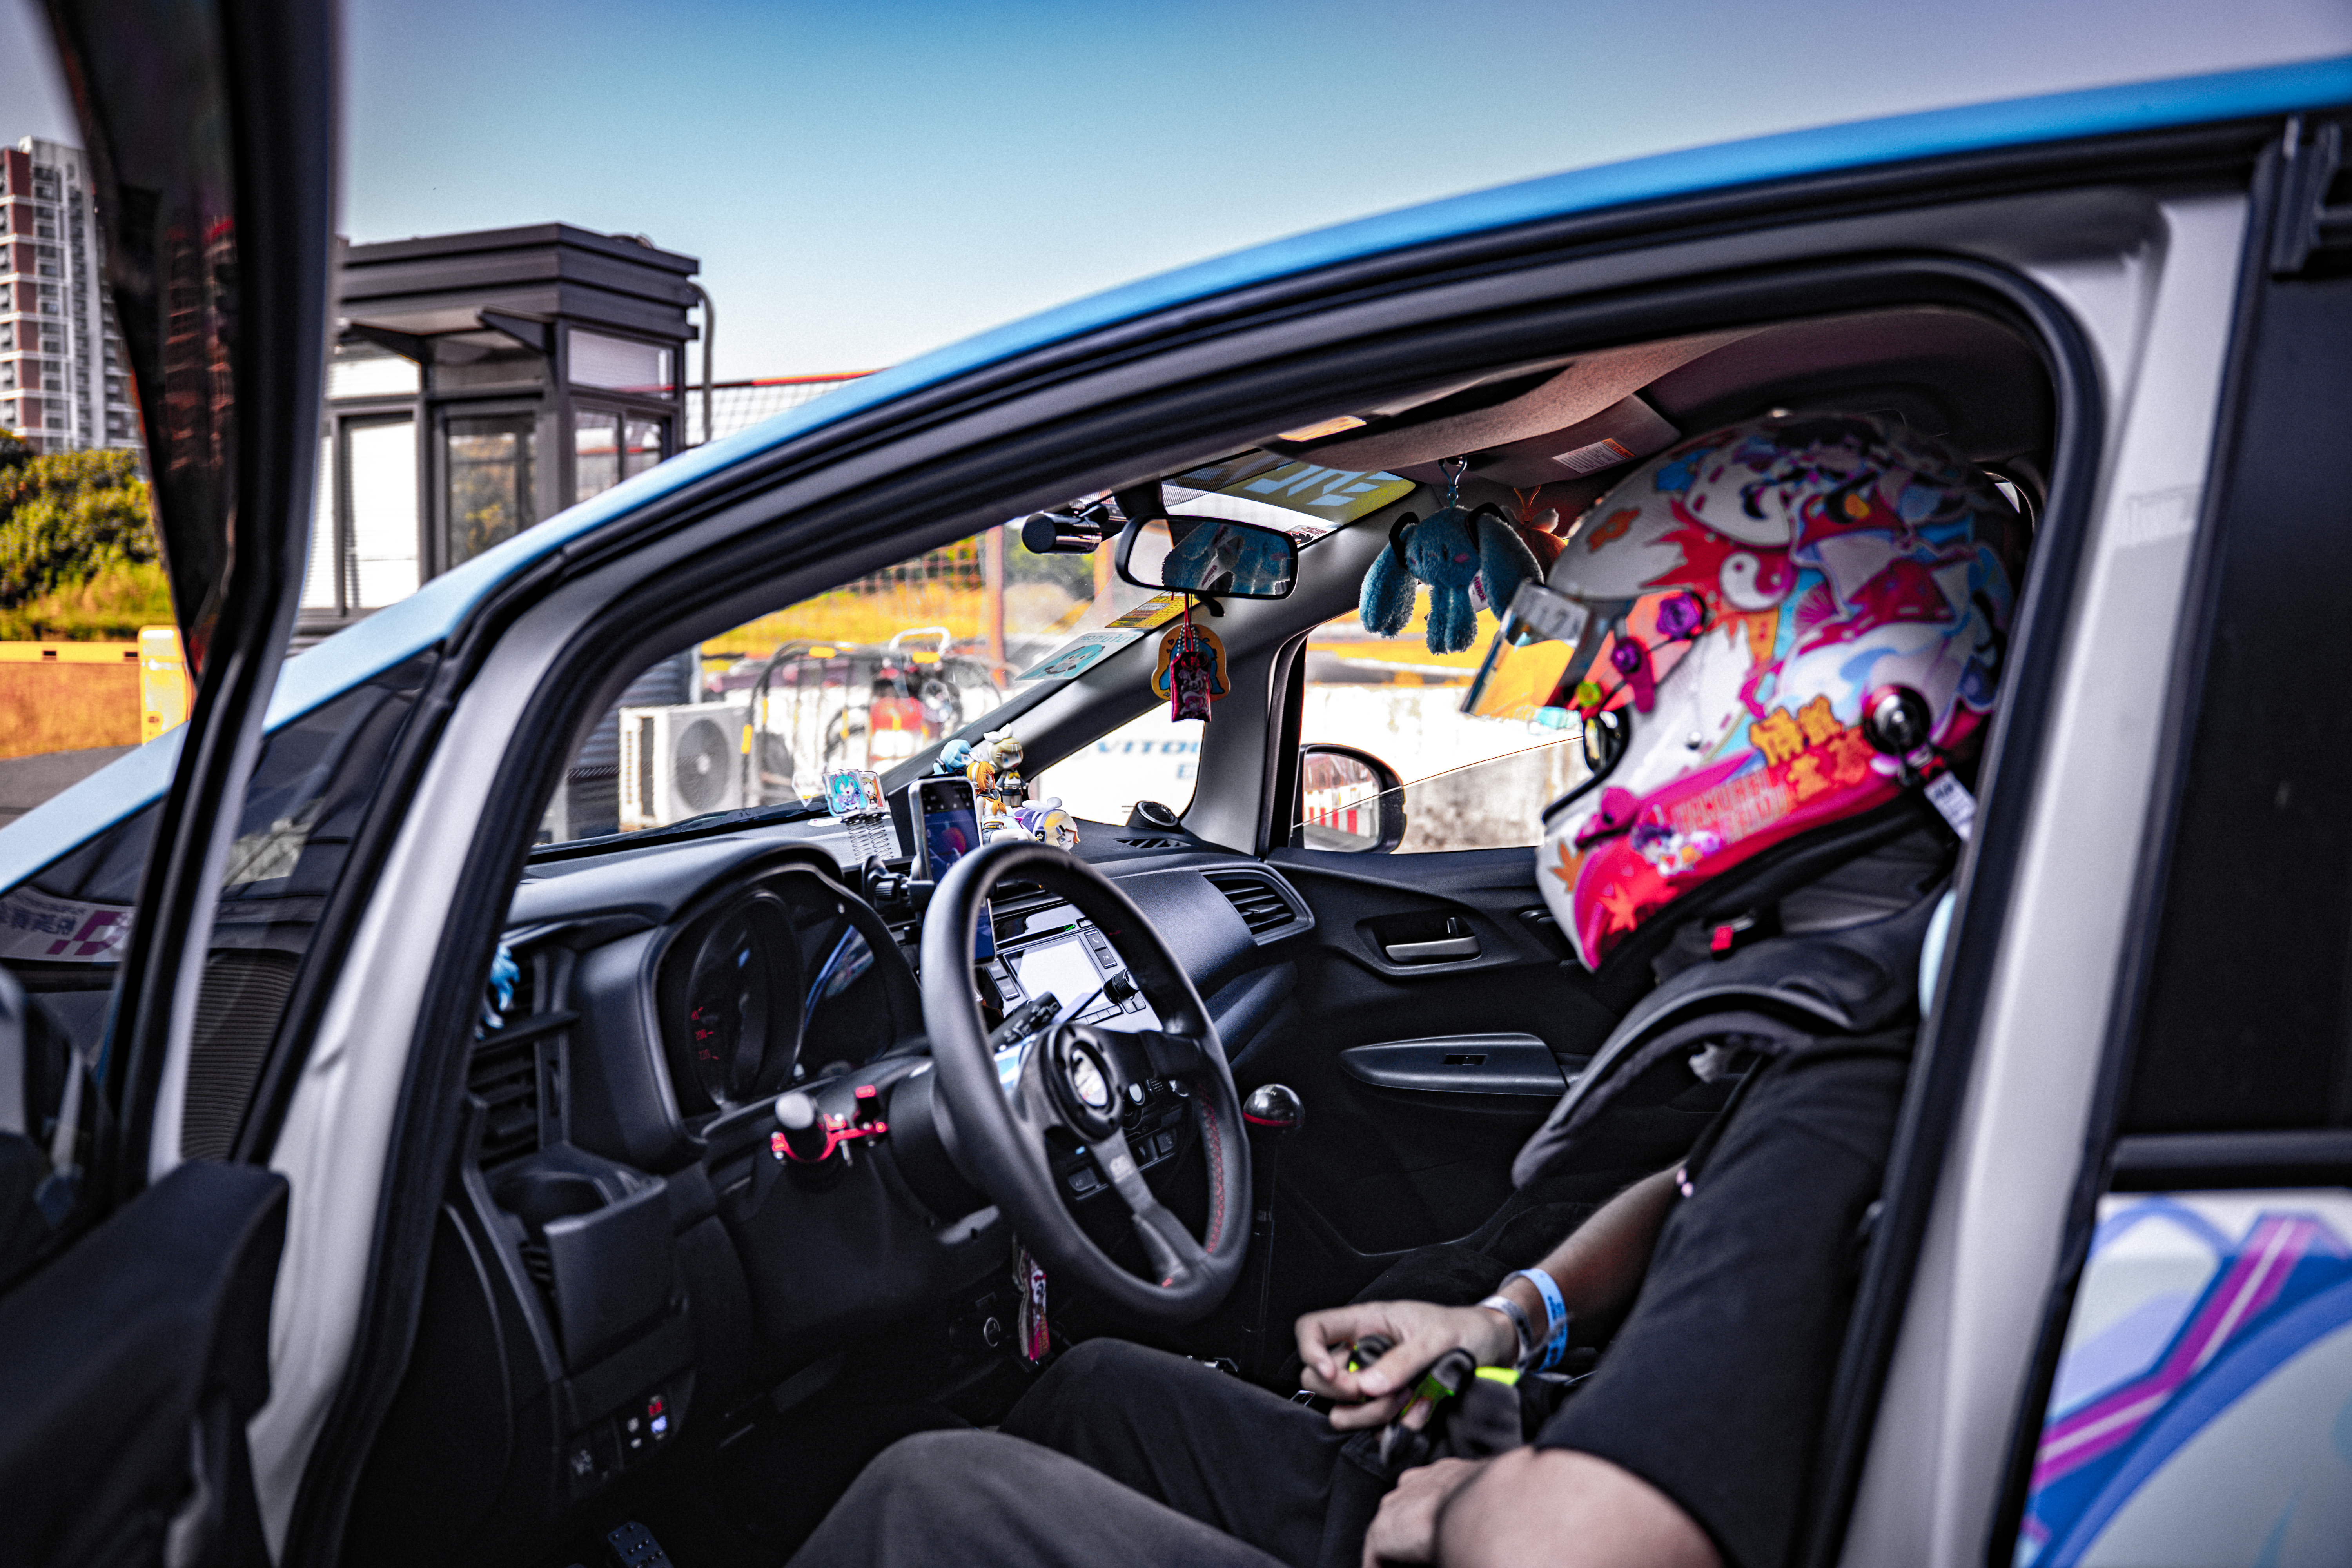
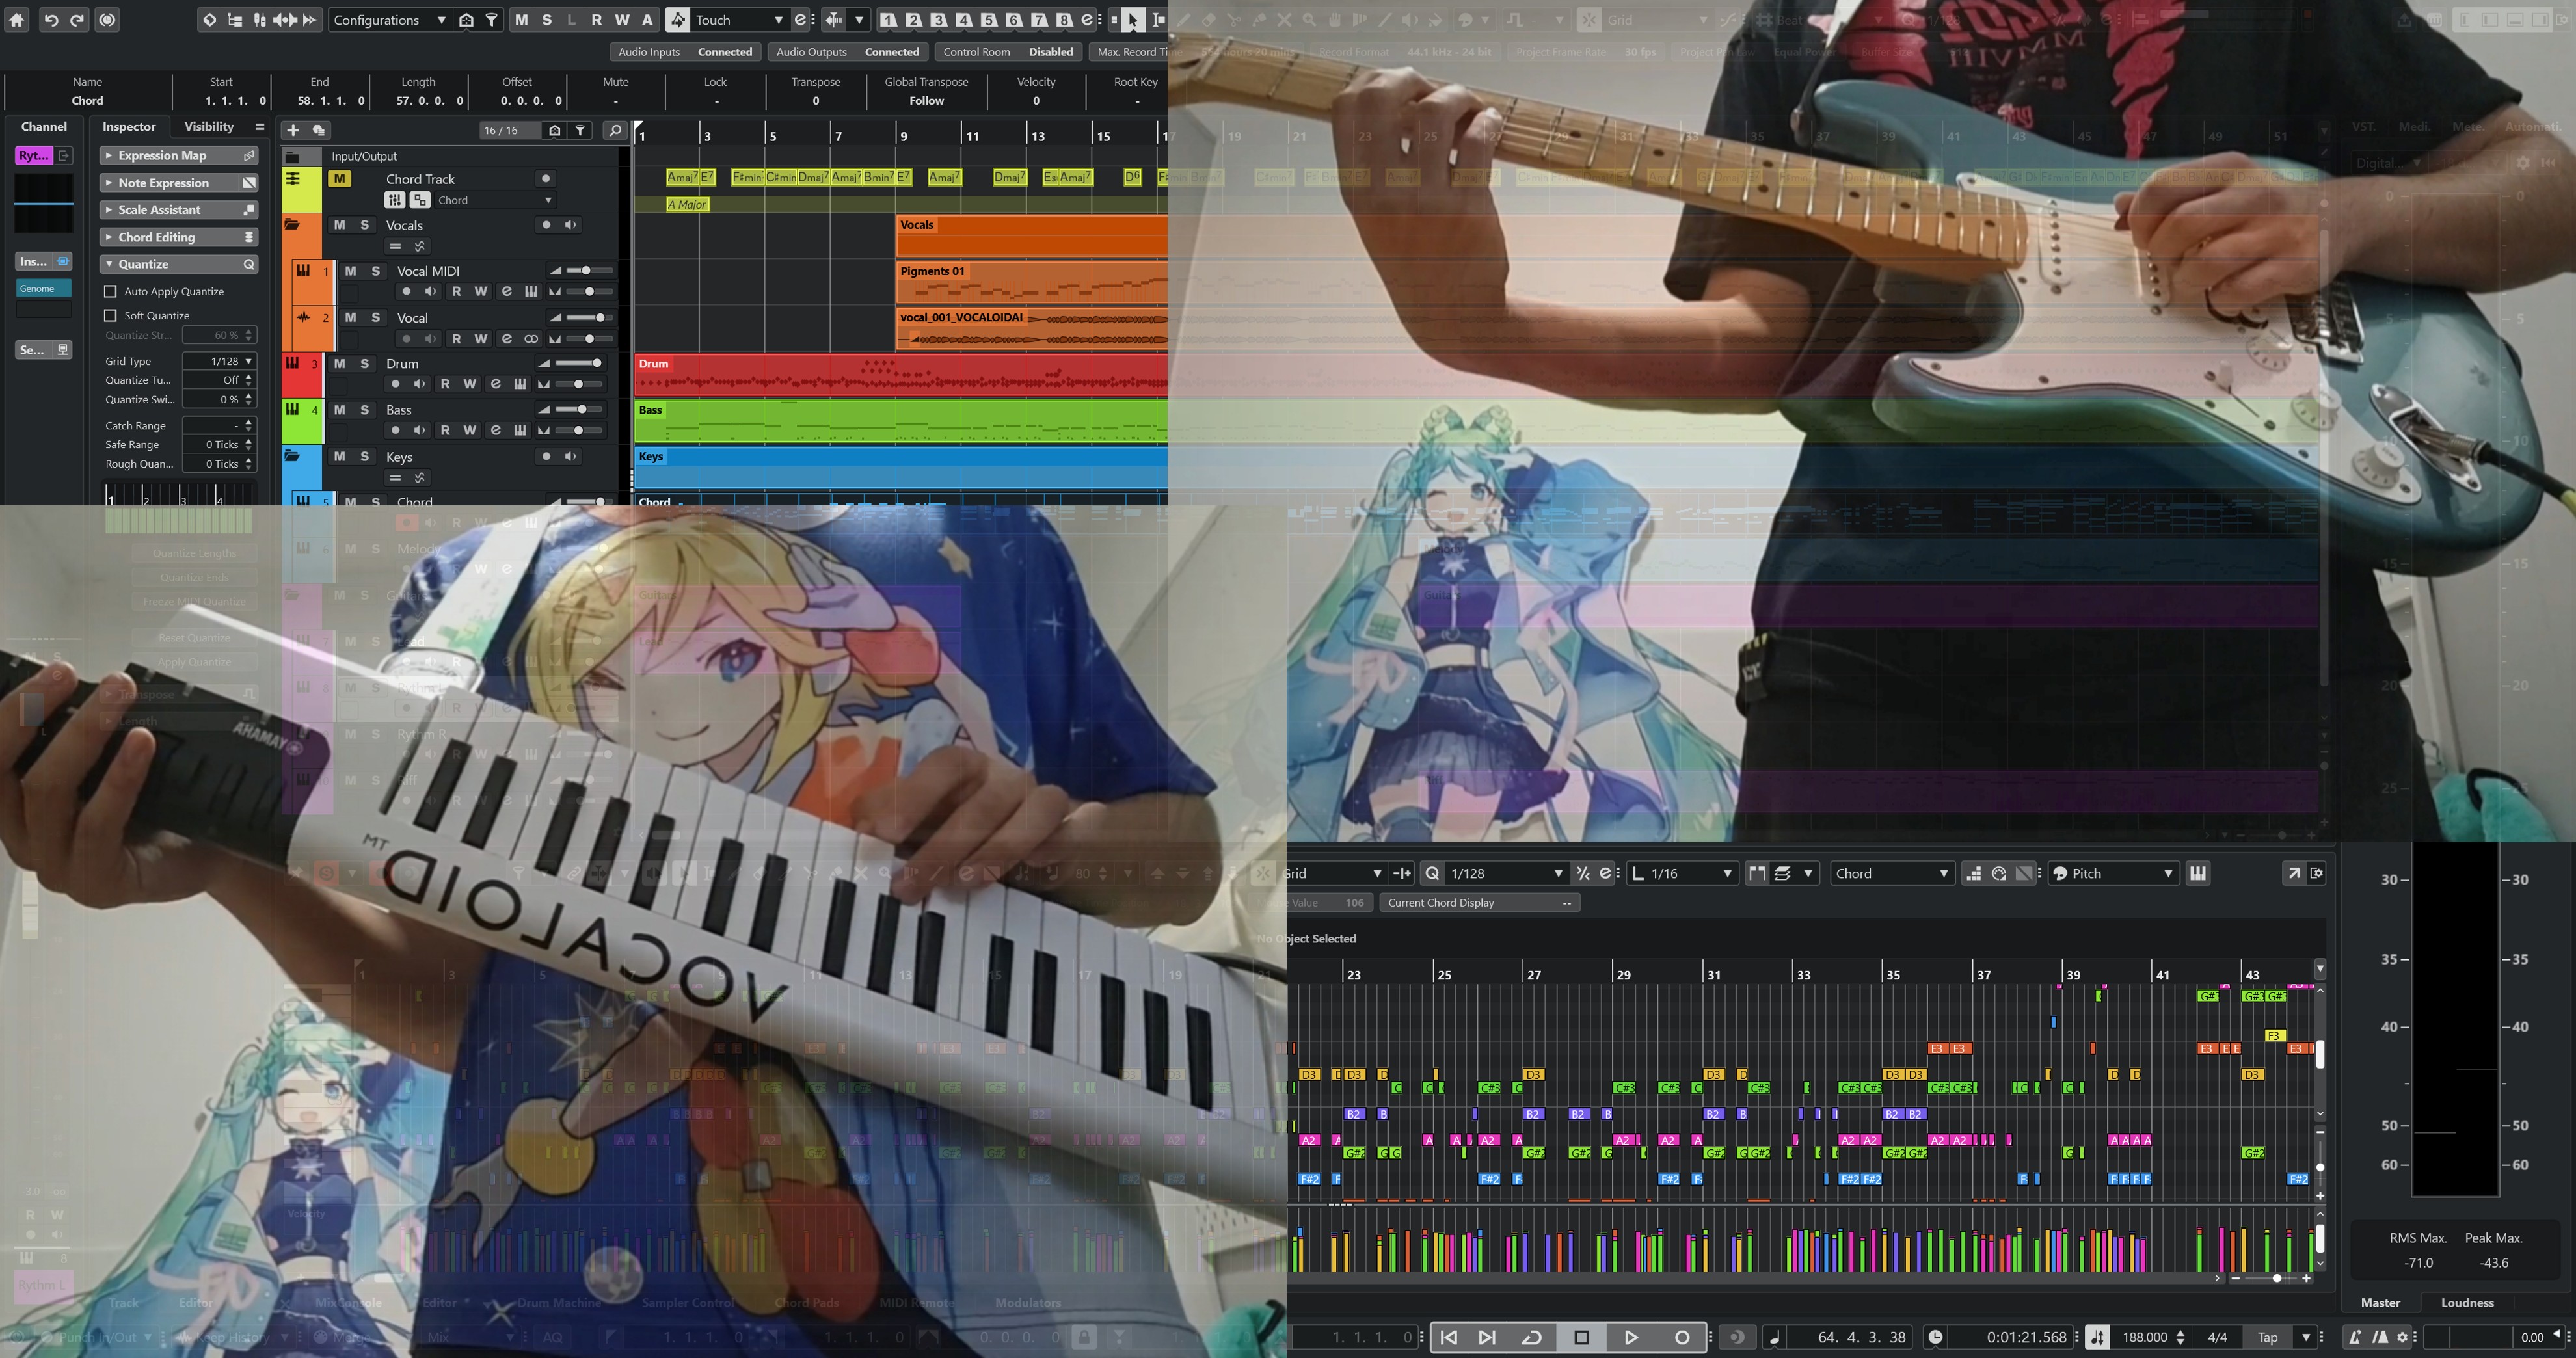
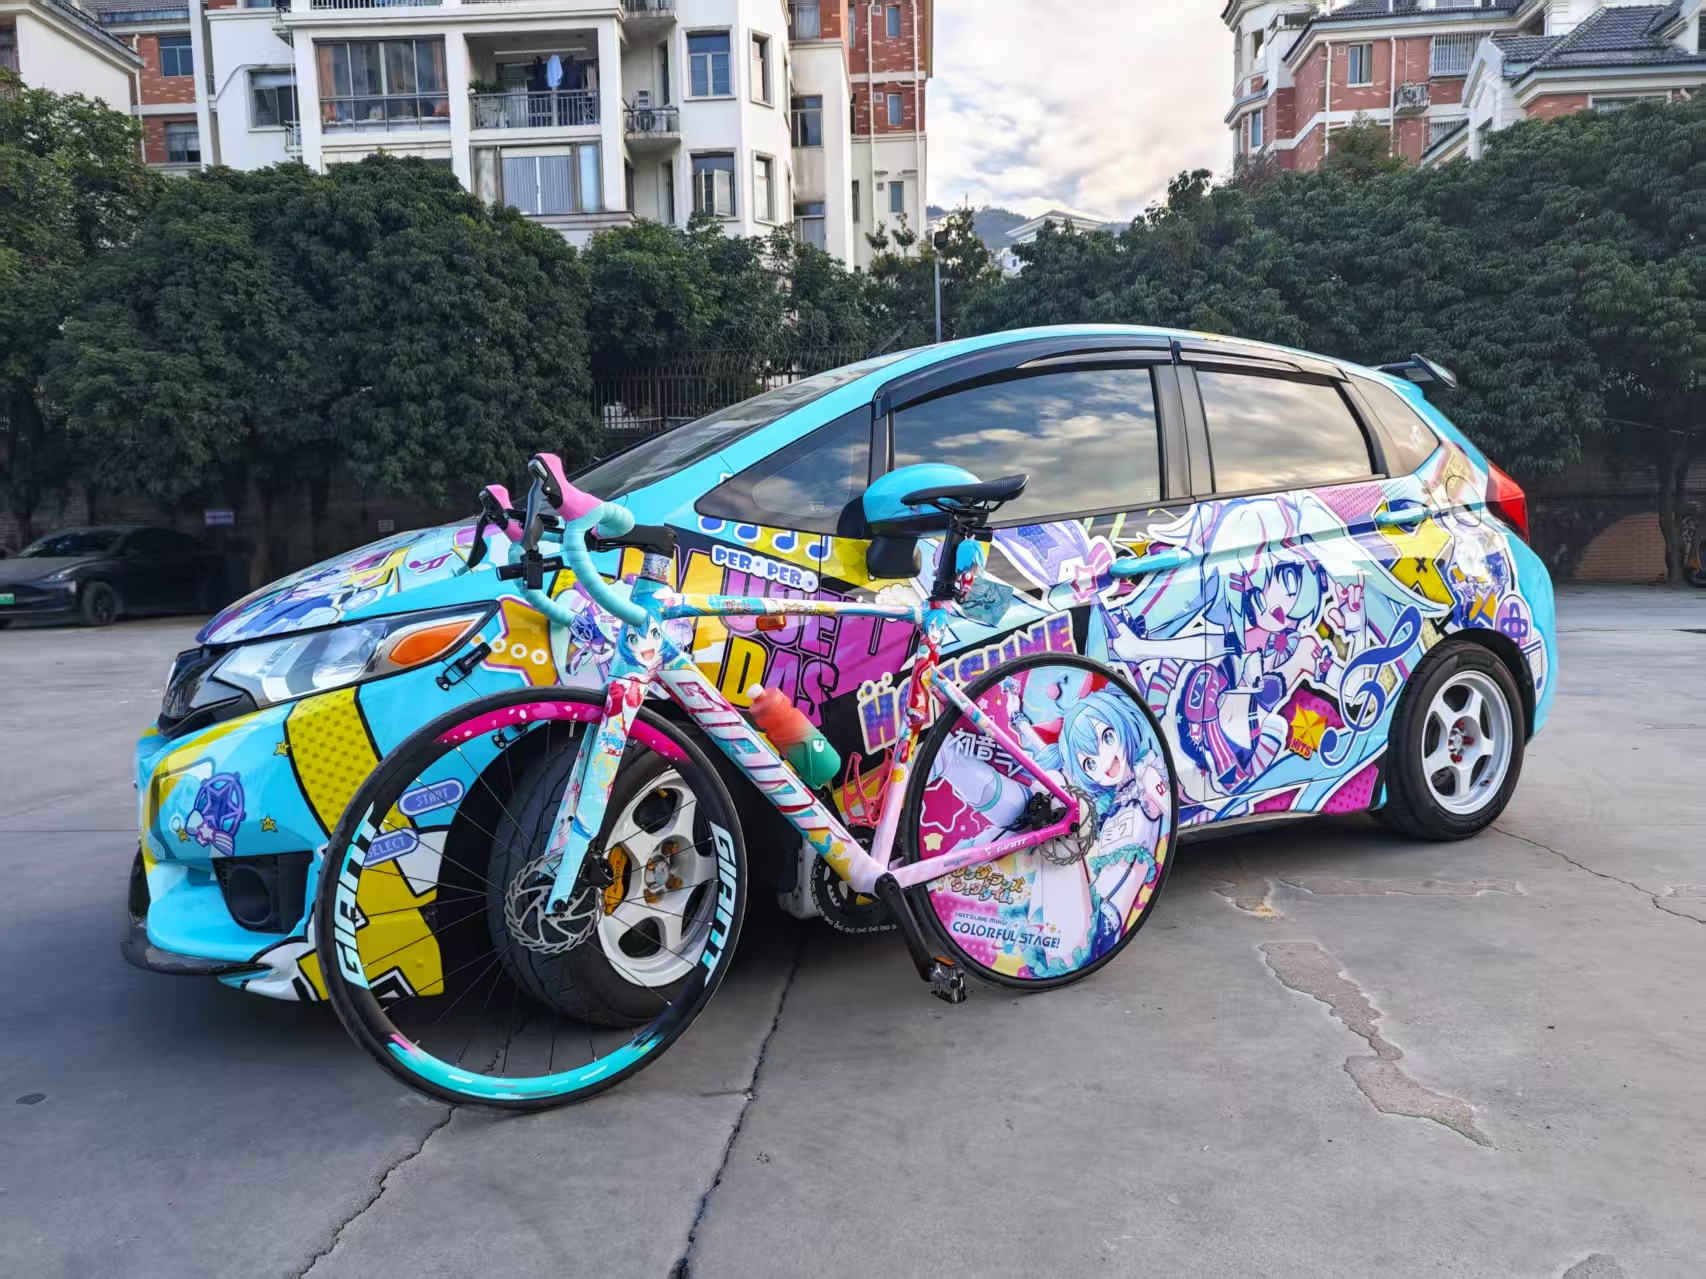
Me in my racing car. Me playing guitar and keytar. I can also compose and arrange music. Me riding my Ita-Bike.

Passionate About Racing and Car Modification
I love the freedom of driving on the racetrack. I own a Porsche 987.2 Boxster S that I have extensively modified myself, and I hope to drive it on famous racetracks around the world. In my spare time, I enjoy karting. I'm also interested in sim racing and have a simulator cockpit in my dorm room.

Big Fan of Music
I'm a big fan of music, especially J-Rock and J-Pop. I play the violin and guitar, and I've recently started learning the piano. I'm also learning music composition and arrangement, particularly for Vocaloid music. I hope to become a Vocaloid P someday.

Standard Otaku
Anime and otaku culture are a big part of my life. I love watching anime, attending anisong concerts, and collecting merchandise. I go by the nickname St@rrySky in the community and at events. My favorite character is Hatsune Miku, a famous virtual singer from Japan. I also own a Hatsune Miku-themed itasha based on the Porsche mentioned above.

Skills
Python   /   C++   /   MATLAB   /   Linux   /   Embedded Systems
CAD   /   PCB Design   /   Fluent English & Japanese